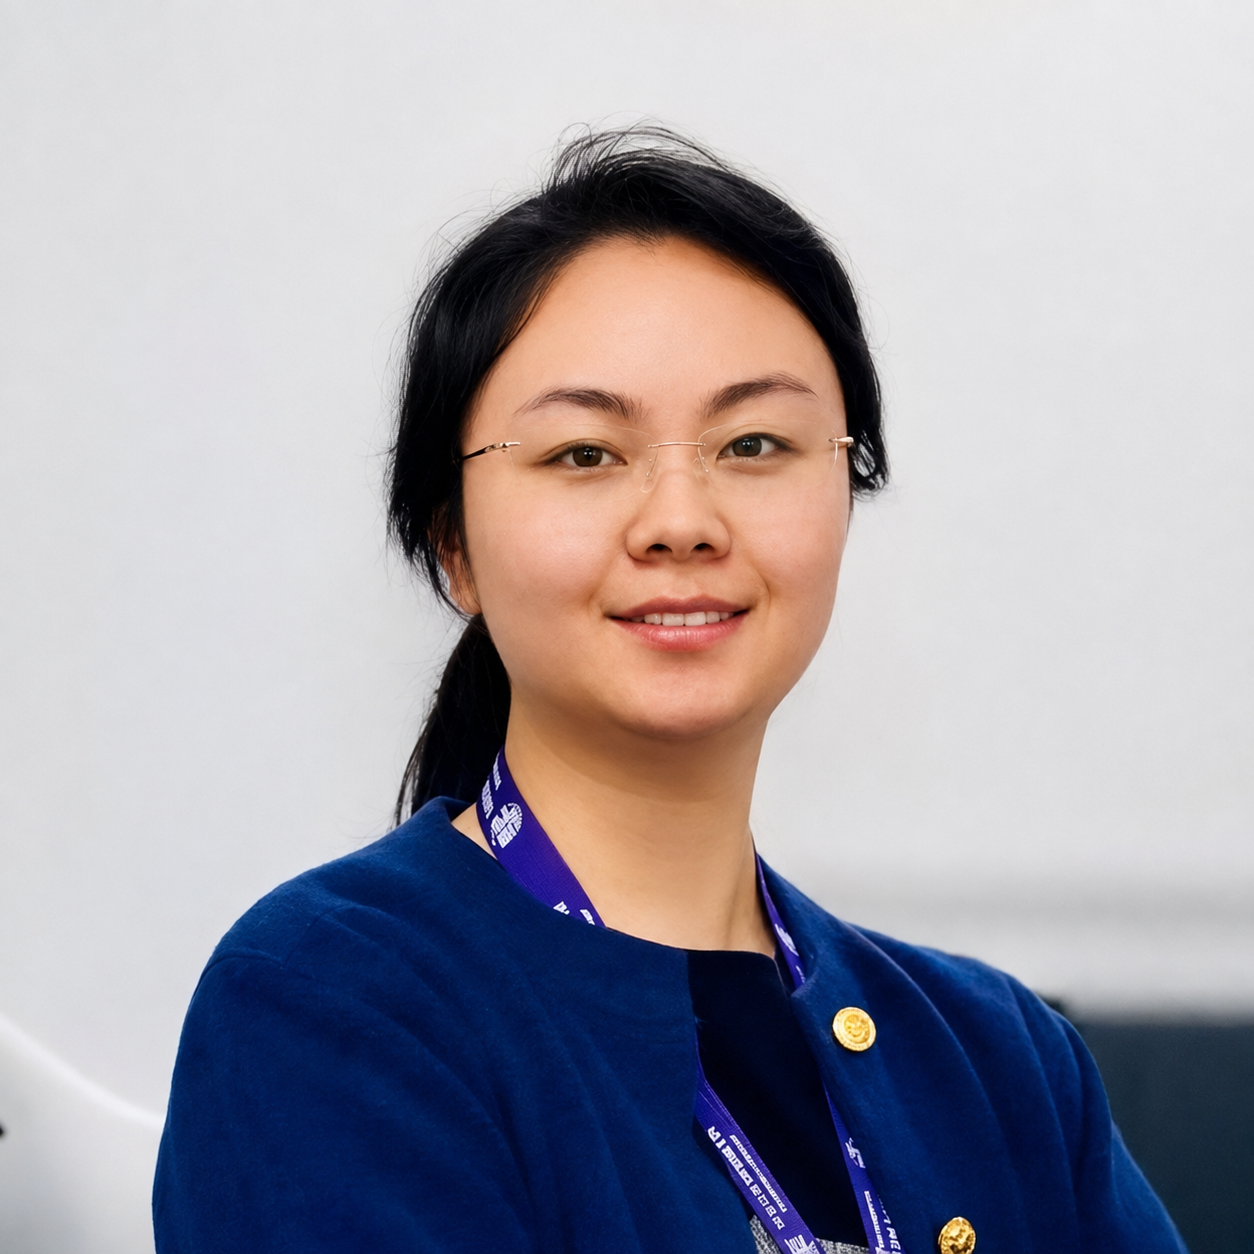
Liman Wang (王莉漫)
I am a 3rd year PhD student in Intelligent Robotics at the University of York, UK, based at the Institute for Safe Autonomy, under the supervision of Dr. Jihong Zhu. Before starting my PhD, I received my Master's degree in Intelligent Robotics from the University of York with Distinction, ranking first in my cohort. Previously, I worked as an Algorithm Engineer at Schneider Electric for three years.
Research Focuses
- Robot Learning in Manipulation
- Dexterous Hands
- VLA models
Selected Publications
MLLM-Fabric: Multimodal Large Language Model-Driven Robotic Framework for Fabric Sorting and Selection
Liman Wang, et al.
Balancing Rigor and Utility: Mitigating Cognitive Biases in Large Language Models for Multiple-Choice Questions
Liman Wang, et al.
Reviewing Service
- IEEE Transactions on Automation Science and Engineering (T-ASE)
- Conference on Robot Learning (CoRL)
- IEEE International Conference on Robotics and Automation (ICRA)
- IEEE Robotics and Automation Letters (RA-L)
- IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- Artificial Intelligence Review (AIR)
- IEEE International Conference on Multimedia & Expo (ICME)
News and Updates
- Oct 2025 Our paper MLLM-Fabric has been accepted to IEEE Robotics and Automation Letters (RA-L) and will be presented at ICRA 2026. Preprint
- Apr 2025 Our work Balancing Rigor and Utility has been accepted as a full paper at CogSci 2025. Preprint
- Jun 2024 I received a full scholarship for my PhD studies at the University of York.
- Apr 2024 Our work LLM-SAP has been accepted to the ICME 2024 Workshop on Multimodal Learning for Social Good.
- Mar 2024 Our work FENet has been accepted to ICME 2024 as an oral paper.
- Dec 2023 Our work Deformable Object Manipulation in Caregiving Scenarios: A Review was published in Machines.
- Nov 2023 I received my Master's degree in Intelligent Robotics from the University of York with Distinction, ranking first in my cohort.
- Jun 2023 I achieved 130% annual performance as an NLP Algorithm Engineer at Schneider Electric (China) Co., Ltd.
- Jun 2022 As an independent inventor, I obtained a national invention patent on knowledge graphs and graph algorithms, issued by the China National Intellectual Property Administration.